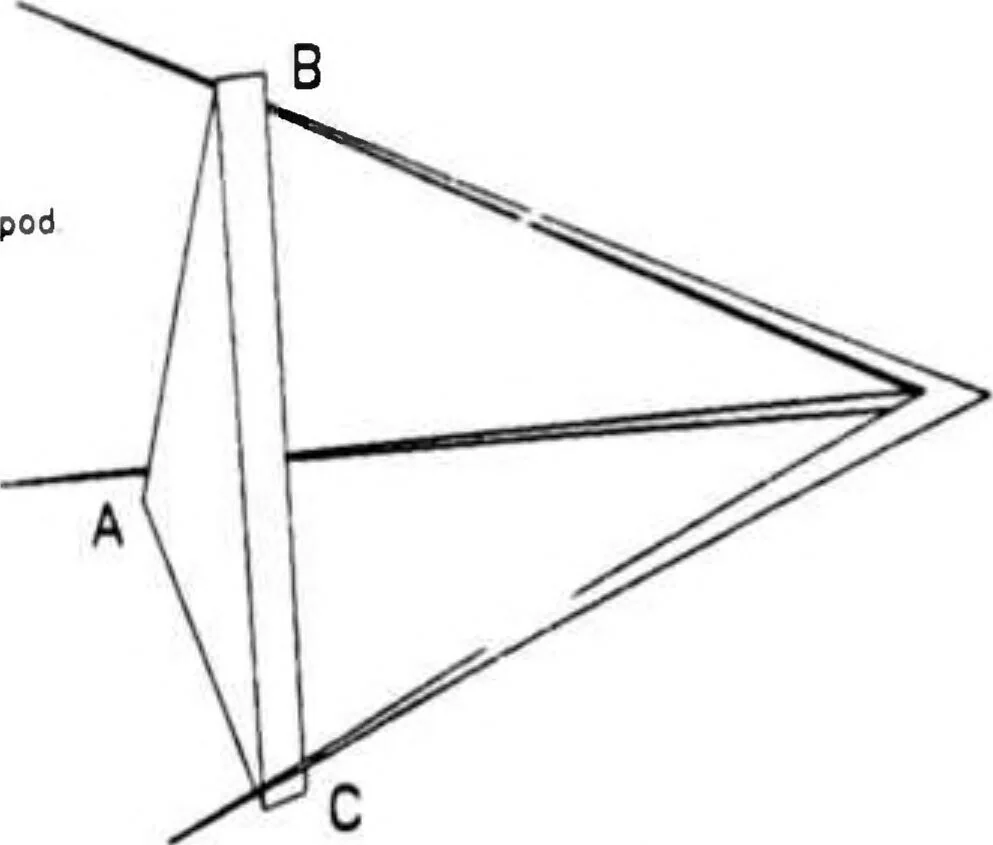
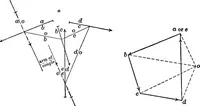
LOCUS SOLVING Camera Locus Solving: One View of Throe Points 9 2 9.2 Camera Locus Solving: One View of Three Points - The Iron Triangle Camera Solving Method. A mobile robot having only visual perception must determine where it is going by what it sees Specifically, the position o* the robot is… … Consider four non-coplanar points A, B, C and L. Let L be the unknown camera’s lens center, also called the camera locus Let A, B and C be the landmark points whose loci either are given on a map or are found by stereo from two already known viewing positions Assuming for the momont an ideal camera…
Baumgart, Bruce Guenther · Stanford univ ca dept of computer science · Computer applications · Computer graphics · Image processing · Artificial intelligence · Computer programming · Semantics · Television cameras · Theses · Three dimensional · Vision
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.