A Distributed Model for Mobile Robot Environment-Learning and Navigation (1990)
Defense Technical Information Center · leaf 102
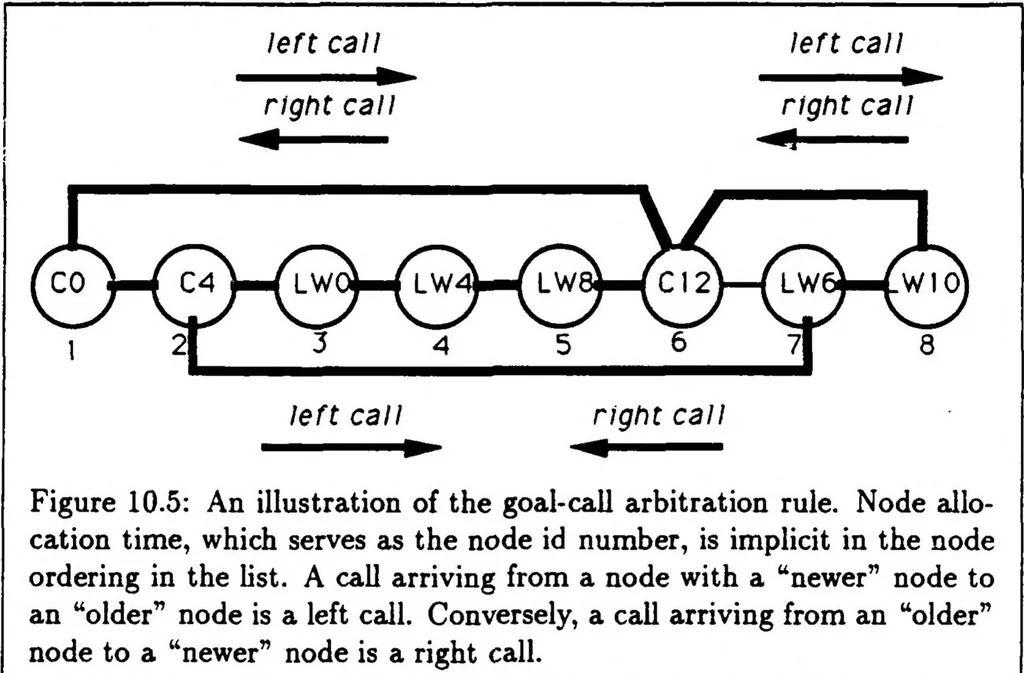
n + 1 . Consequently, the nodes are ordered by discovery time. Any node on the left is “older” than all nodes on the right of it in the list. (Note that the sense in which a node is “old” is reversed from chronological age as reflected in its id number.) A simple division of all calls can be made…
Mataric, Maja J · Massachusetts inst of tech cambridge artificial intelligence lab · Omnidirectional · Autonomous navigation · Robots · Detectors · Models · Real time · Distribution · Dynamics · Layers · Physical properties · Graphs · Paths · Theses · Reactivities · Nodes · Ultrasonics · Planning · Mobile · Barriers · Low level · Language · Maps · Power · Behavior · Architecture · Learning · Navigation reference · Detection · Environments · Methodology · Experimental data
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.