A Distributed Model for Mobile Robot Environment-Learning and Navigation (1990)
Defense Technical Information Center · leaf 105
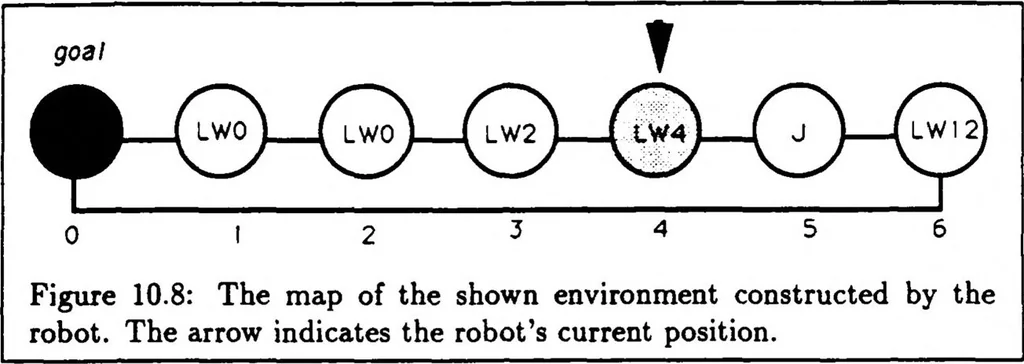
physical one. Figure 10.9 shows the main parts of the trace of the robots path as it progresses toward the goal. The complete trace is shown in Appendix C. Using the estimated landmark length (see chapter 8) the robot correctly chooses the topologically longer but physically shorter path to the…
Mataric, Maja J · Massachusetts inst of tech cambridge artificial intelligence lab · Omnidirectional · Autonomous navigation · Robots · Detectors · Models · Real time · Distribution · Dynamics · Layers · Physical properties · Graphs · Paths · Theses · Reactivities · Nodes · Ultrasonics · Planning · Mobile · Barriers · Low level · Language · Maps · Power · Behavior · Architecture · Learning · Navigation reference · Detection · Environments · Methodology · Experimental data
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.