A Distributed Model for Mobile Robot Environment-Learning and Navigation (1990)
Defense Technical Information Center · leaf 36
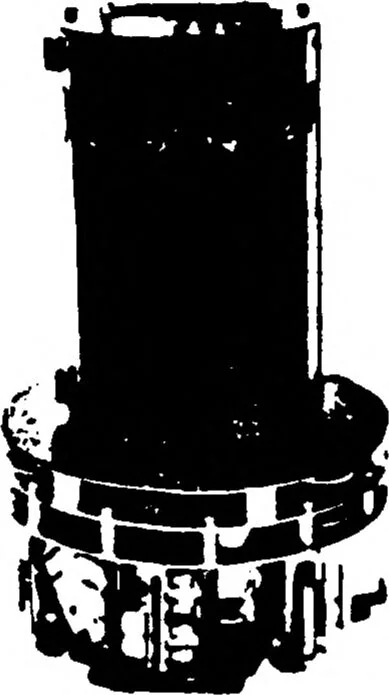
1 2 tn 8in -m I. … Figure 4.1: The robot: an omnidirectional three-wheeled base equipped with a ring of 12 sonars and a compass. which would be observed in the real world. In order to avoid both the difficulties and pitfalls of simulation, a physical robot, Toto, was constructed for testing and debugging all…
Mataric, Maja J · Massachusetts inst of tech cambridge artificial intelligence lab · Omnidirectional · Autonomous navigation · Robots · Detectors · Models · Real time · Distribution · Dynamics · Layers · Physical properties · Graphs · Paths · Theses · Reactivities · Nodes · Ultrasonics · Planning · Mobile · Barriers · Low level · Language · Maps · Power · Behavior · Architecture · Learning · Navigation reference · Detection · Environments · Methodology · Experimental data
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.