A Distributed Model for Mobile Robot Environment-Learning and Navigation (1990)
Defense Technical Information Center · leaf 69
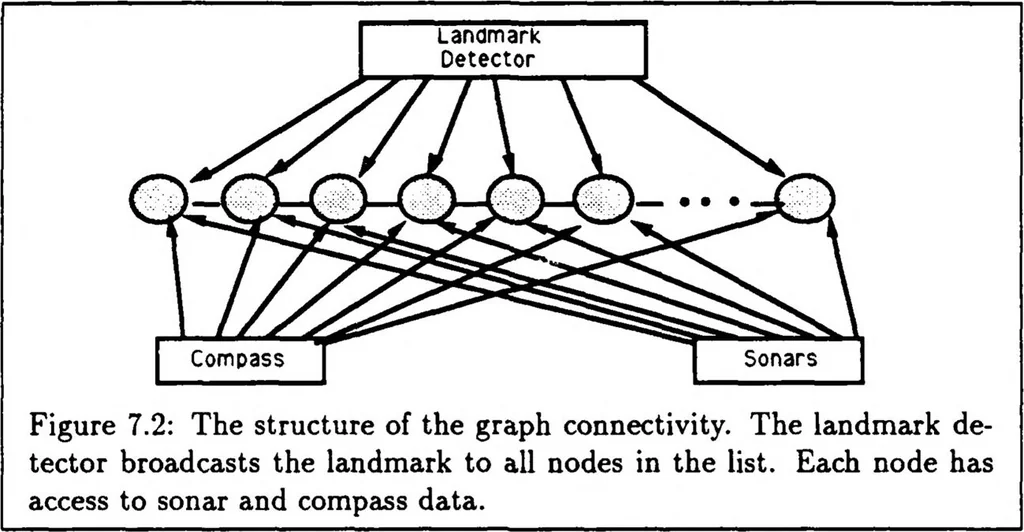
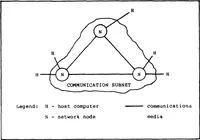
a detailed discussion). The robot is initially given an underlying graph with “empty” nodes which are “filled” sequentially, as it explores its environment. The nodes are interconnected by message wires which allow communication between nearest neighbors in the graph. The graph connectivity is a…
Mataric, Maja J · Massachusetts inst of tech cambridge artificial intelligence lab · Omnidirectional · Autonomous navigation · Robots · Detectors · Models · Real time · Distribution · Dynamics · Layers · Physical properties · Graphs · Paths · Theses · Reactivities · Nodes · Ultrasonics · Planning · Mobile · Barriers · Low level · Language · Maps · Power · Behavior · Architecture · Learning · Navigation reference · Detection · Environments · Methodology · Experimental data
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.