A Distributed Model for Mobile Robot Environment-Learning and Navigation (1990)
Defense Technical Information Center · leaf 93
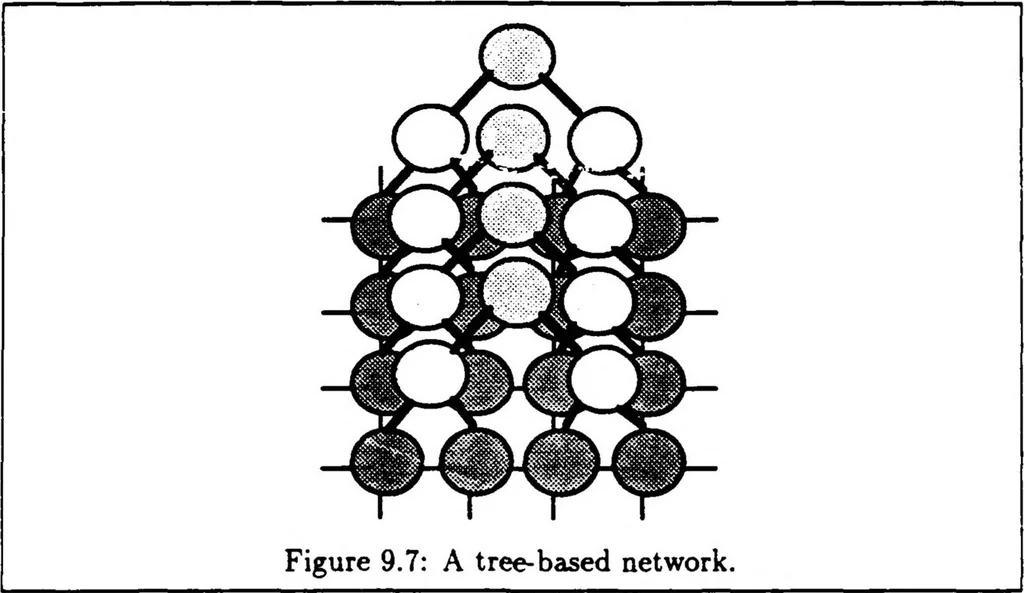
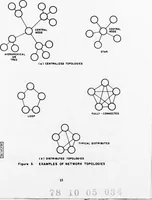
is chosen, it invalidates the entire parent tree. While some of these data structures may appear appropriate, they at¬ tempt to optimize a different metric than that being explored for the purpose of map construction. The goal of the data structure is to avoid having to reuse links connecting the…
Mataric, Maja J · Massachusetts inst of tech cambridge artificial intelligence lab · Omnidirectional · Autonomous navigation · Robots · Detectors · Models · Real time · Distribution · Dynamics · Layers · Physical properties · Graphs · Paths · Theses · Reactivities · Nodes · Ultrasonics · Planning · Mobile · Barriers · Low level · Language · Maps · Power · Behavior · Architecture · Learning · Navigation reference · Detection · Environments · Methodology · Experimental data
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.