Design of an Artificial Neural Network Based Tactile Sensor for the UTAH/MIT Dexterous Hand (1992)
Defense Technical Information Center · leaf 67
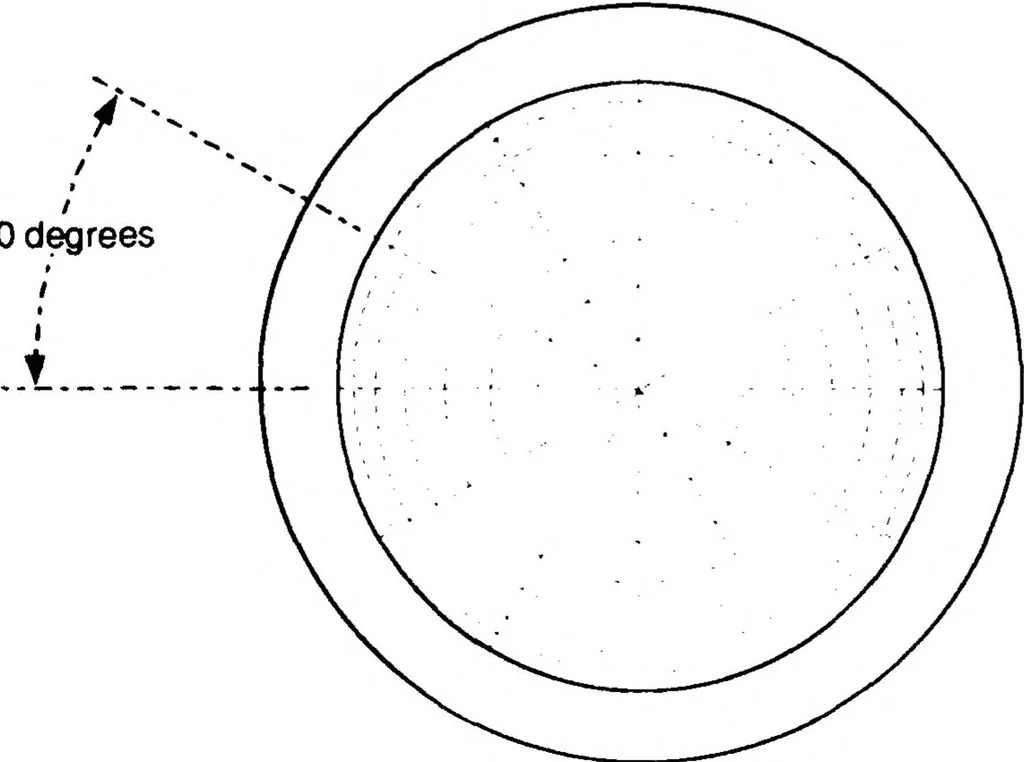
ASPECT VIEW TOP VIEW … Figure 5. 1 Training Map for Spherical Tip of the NTS prototype for the Utah/MIT Dexterous Hand Showing The 10° Latitude and 30° Longitude spacing between Training Data Sites. (Dotted -line Intersections represent Training Data Sites)
Nering, Jeffery D · Air force inst of tech wright-patterson afb oh school of engineering · Neural nets · Pattern recognition · Skin(anatomy) · Artificial intelligence · Touch · INPUT · Output · Resolution · Electric fields · Senses(physiology) · Trajectories · Electrodes · High resolution · Voltage · Networks · Measurement
Internet Archive · Defense Technical Information Center · Public domain (US government work). Free to use for anything.