Analytical mechanics for students of physics and engineering (1913)
Dadourian, Haroutune Mugurditch, 1878- · New York, D. Van Nostrand company · leaf 24
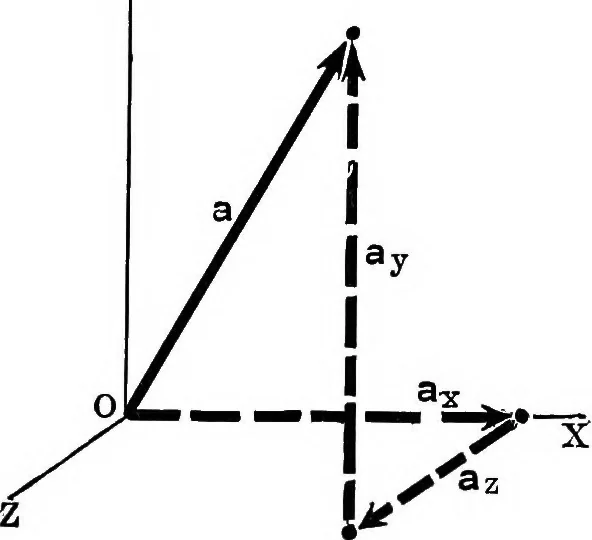
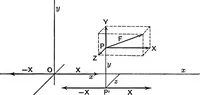
Fig. 9. * The sjrmbol = will be used to denote approximate equality. There-fore = should be read equals approximately, or equals about, orequals nearly. See table of notations, p. x. ADDITION AND RESOLUTION OF VECTORS 9 a — Sx ~r a-K)ax= a cos 8, tty — a sin 0, a = ^aJ^+Uy^, ax When a has… … Fig. 10. a ^ ai -p a^/ -p- a^.ax= a cos ai,ay= a cos a2,a^= a cosaa. (IV)(V) a = VaJ+Oy^+a?, (VI) where ai, a-i, and az are the angles a makes with the coordi-nate axes. 14. Resultant of Any Number of Vectors. Graphical Methods.— The resultant of a number of vectors a, b, c, etc., may beobtained by…
Mechanics, Analytic
Internet Archive · Cornell University Library · Public Domain Mark 1.0. Free to use for anything.